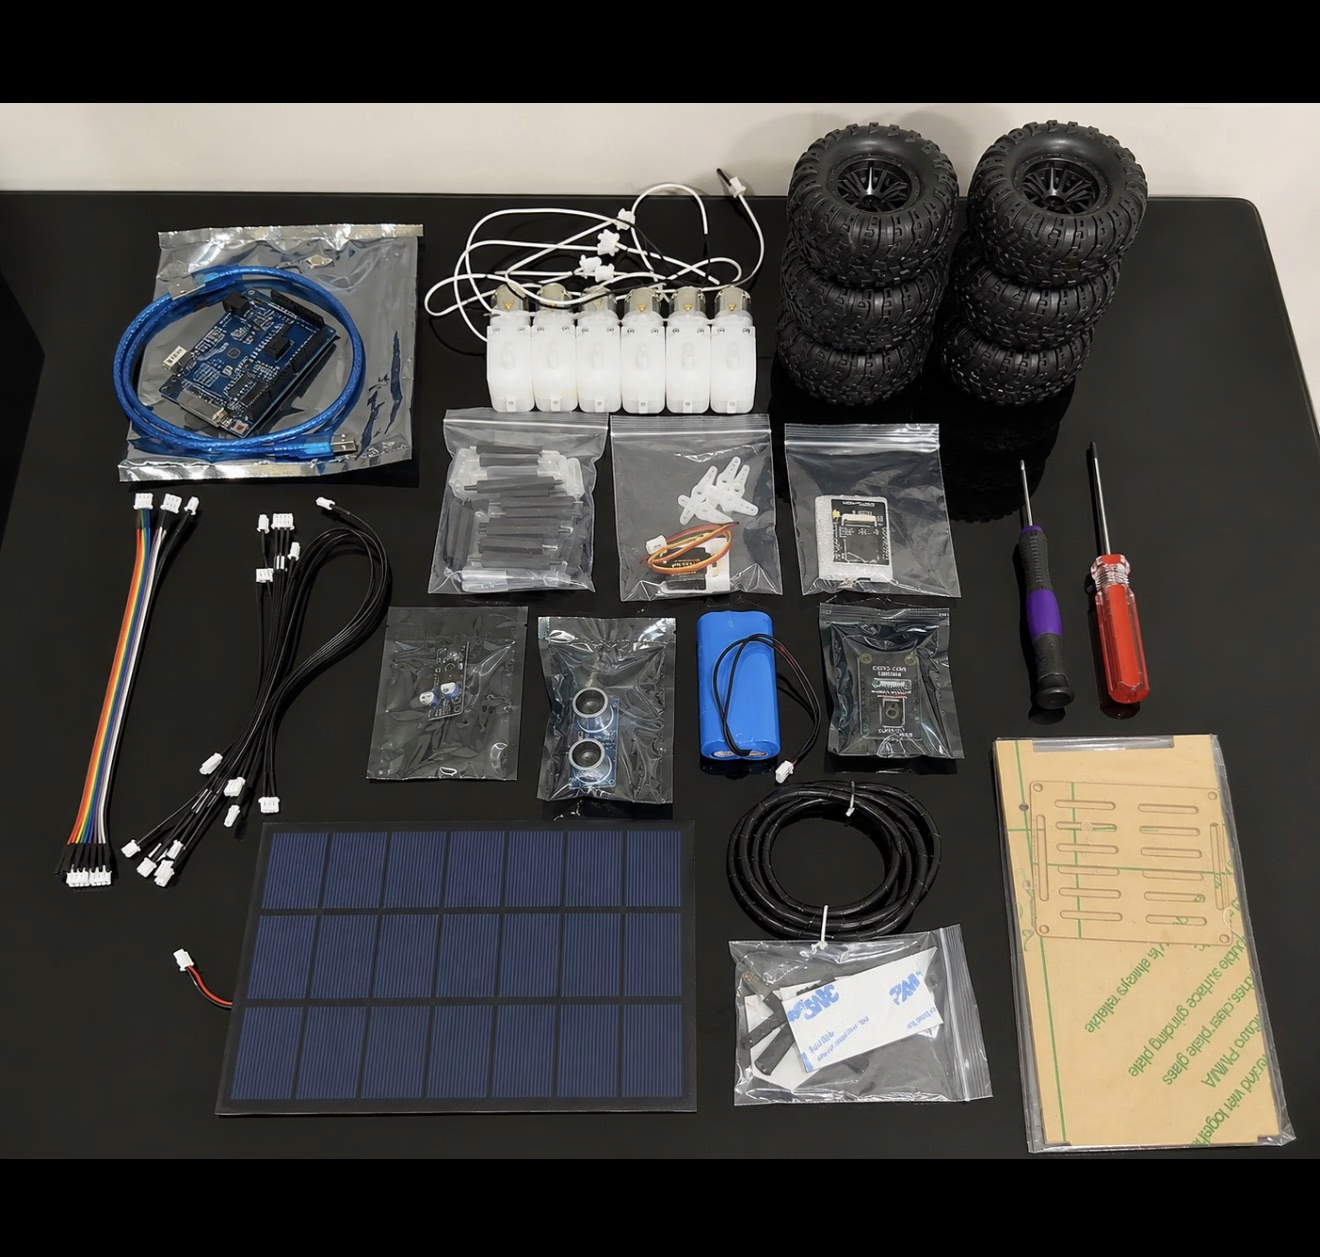
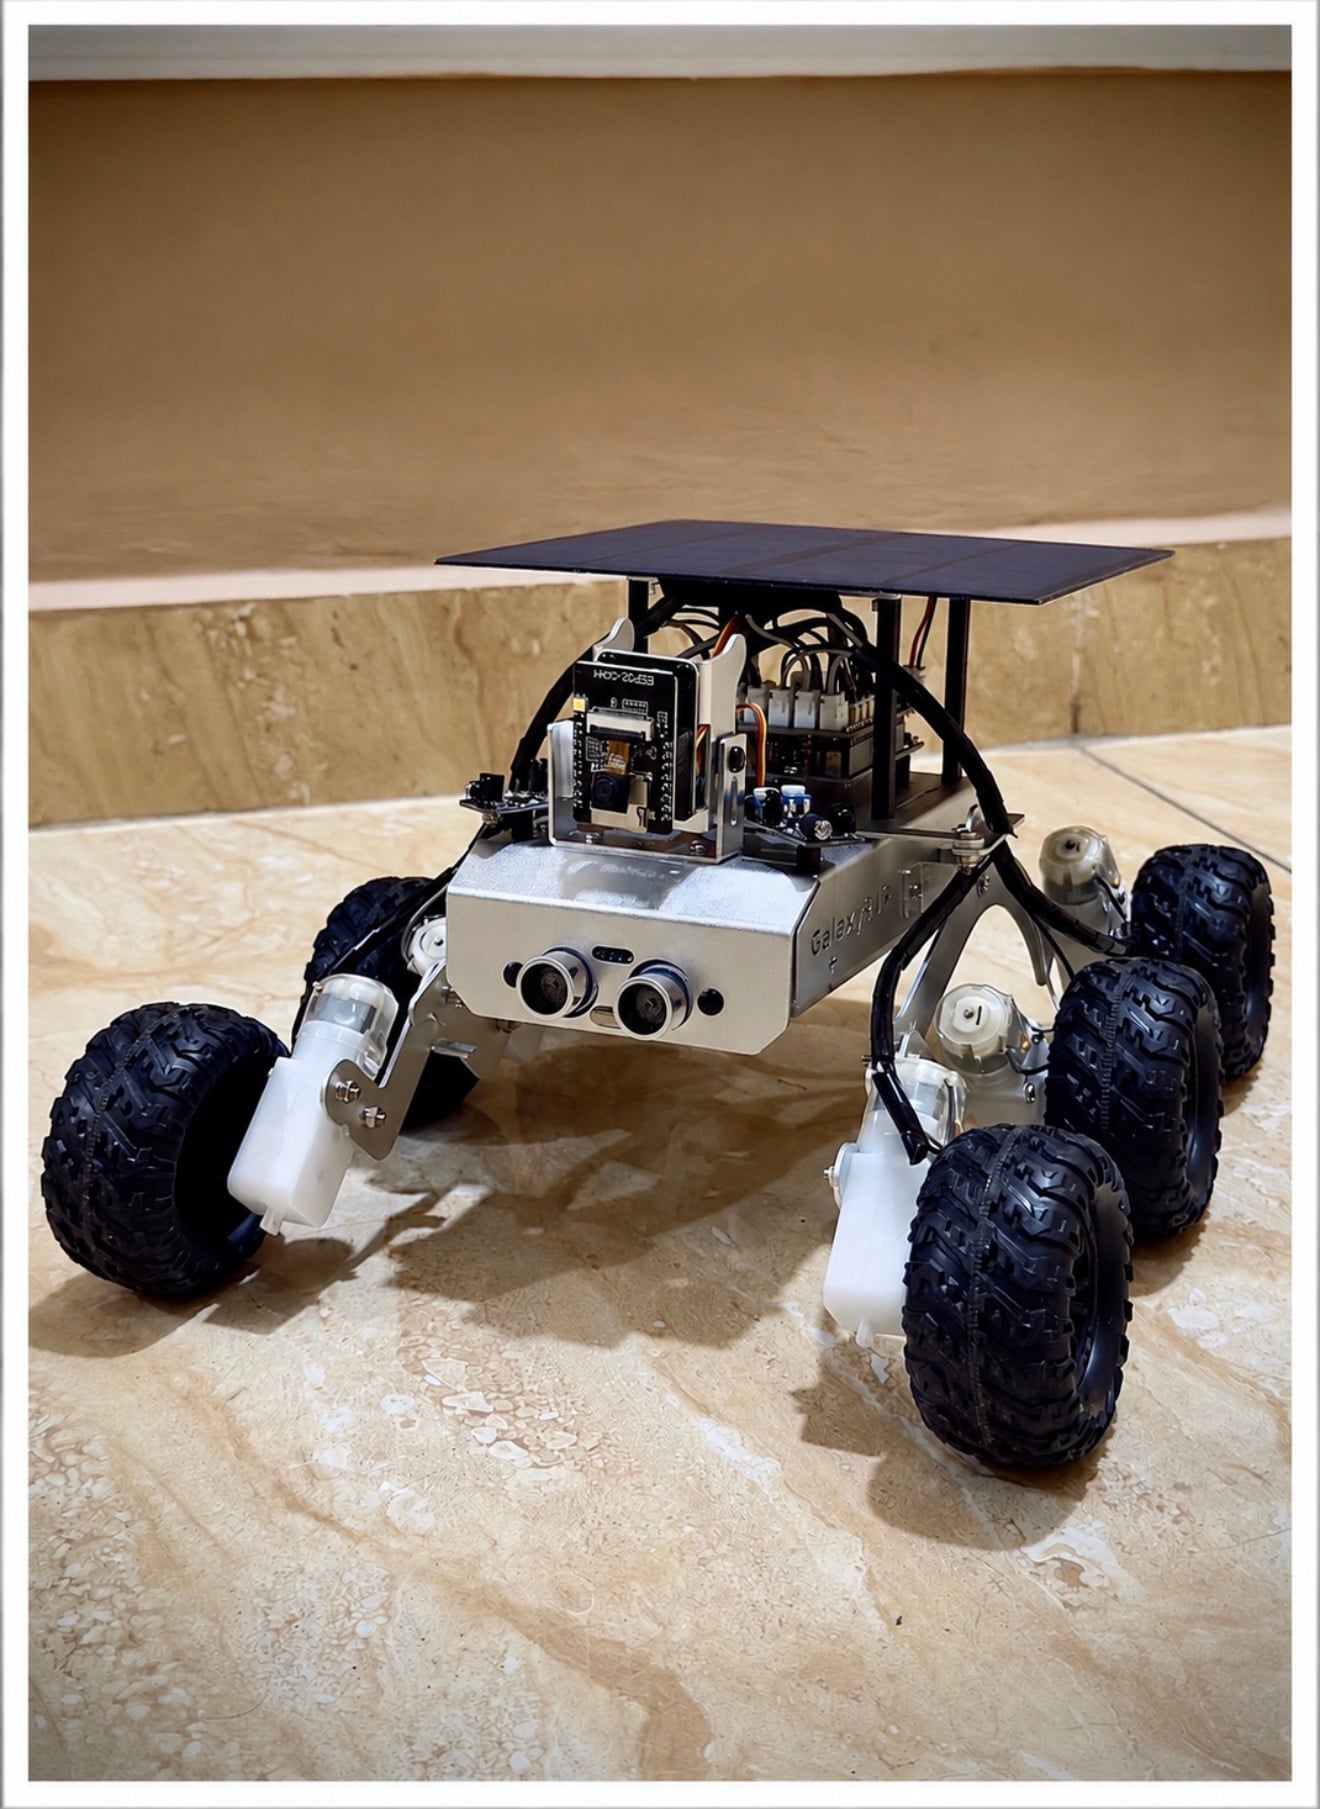
AUTONOMOUS AI ROVER
Arduino Uno R3 rover with obstacle avoidance, Wi-Fi and voice control, FPV streaming, and solar-assisted charging.
The Problem
Chassis misalignment reduced mobility.
Communication latency between sensors, motors, and controllers.
The Solution
Recalibrated sensors and refined the obstacle avoidance algorithm.
Tuned the chassis and drivetrain for smoother movement.
Optimized controller communication for reliable real-time operation.